Andong Yang
Hi there! I work on multi-robot systems with aerial, wheeled, and legged robots.
Thank you for your interest! I am a postdoctoral researcher at Tsinghua University, working with Professor Lu Fang and Professor Chao Gao. I enjoy building new robots and exploring algorithms that make them more capable and intelligent. My research involves physical intelligence, decentralized coordination, and motion planning in multi-robot systems.
Andong Yang is a postdoctoral researcher at Tsinghua University, working with Professor Lu Fang and Professor Chao Gao. He received his PhD from the Institute of Computing Technology, Chinese Academy of Sciences, where he was supervised by Professor Yu Hu and Professor Wei Li. His research focuses on multi-robot systems that combine aerial, ground, and legged robots, spanning coordination, motion planning, and whole-body control. He currently leads an air-ground collaborative exploration project and the algorithm team of a multi-humanoid collaborative transport project.
Formal Bio Github G. Scholar LinkedIn
Internship opportunities are available, and I'm always open to collaboration. Feel free to contact me: andongyang24@gmail.com
Education and Academic Positions
- Mar 2025 - Present Postdoc, Tsinghua University, Beijing
- Sep 2019 - Jan 2025 Ph.D., Institute of Computing Technology, Chinese Academy of Sciences, Beijing
- Sep 2015 - Jul 2019 B.Eng., Dalian University of Technology, Dalian
Professional Services
- Reviewer, IEEE Transactions on Pattern Analysis and Machine Intelligence (TPAMI)
- Reviewer, IEEE Transactions on Robotics (TRO)
- Reviewer, IEEE Robotics and Automation Letters (RA-L)
- Reviewer, IEEE International Conference on Robotics and Automation (ICRA)
- Reviewer, IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
- Teaching Assistant, Computer Architecture
- Member, Career Development Association, ICT, CAS
- Member, Student Union, University of Chinese Academy of Sciences
Honors and Awards
- Second Prize in Obstacle Avoidance and Highway Driving, World Intelligent Driving Challenge
- Academic First-Class Scholarship, ICT, Chinese Academy of Sciences
- Merit Student, ICT, Chinese Academy of Sciences
How can drones improve the navigation performance of ground robots?
Ongoing work
How can ground robots collaborate to carry a load?
Ongoing work
How well can a world model perform on depth-to-action policies for drones?
Under review
How can a humanoid robot handle terrain when a typical blind spot is present?
Under review
Can we treat multimodal robot inputs like word embeddings in long-horizon tasks?
Under review
How can we build a mobile robot that performs well in wild environments?
- Sms-mpc: Adversarial learning-based simultaneous prediction control with single model for mobile robots
- Speed planning based on terrain-aware constraint reinforcement learning in rugged environments
- F3dmp: Foresighted 3d motion planning of mobile robots in wild environments
- Scoml: Trajectory planning based on self-correcting meta-reinforcement learning in hybrid terrain for mobile robot
- Vibration-Aware Trajectory Optimization for Mobile Robots in Wild Environments via Physics-Informed Neural Network
Mobile Robot Systems in Challenging Environments
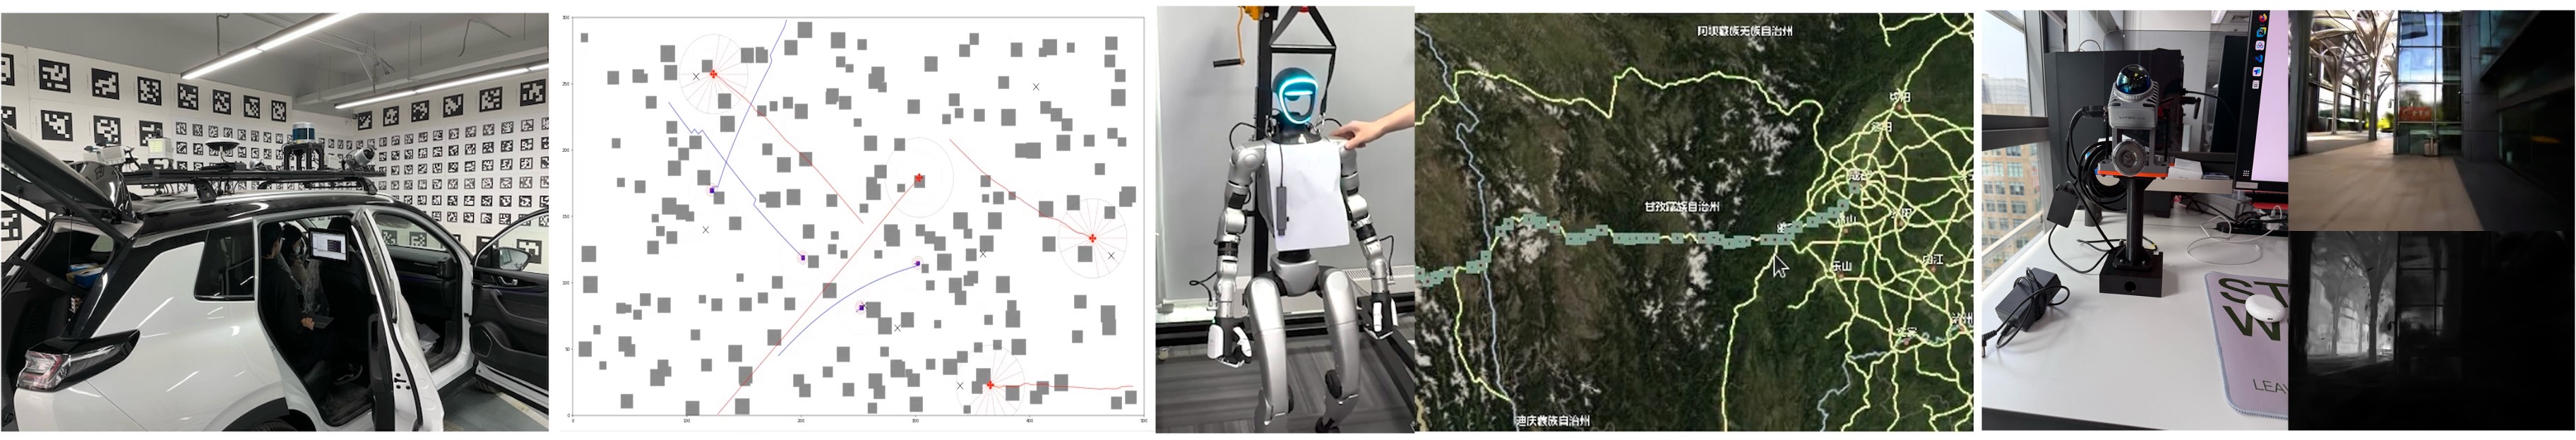
Motion planning and control in forests and plateaus. F3DMP and SCOML frameworks.
Self-Driving Car for Plateau Environment
Autonomous driving without HD maps using LiDAR, cameras, and GPS.
Air-Ground Collaborative Exploration Systems
Heterogeneous UAV and ground robots for large-scale exploration.
Pure Neural Drone Flying with Optical Chip
End-to-end neural flight stack replacing traditional planning and PX4 pipelines.
3D Gaussian-Based Building Reconstruction
Large-scale 3D Gaussian splatting for building and outdoor scene reconstruction.
Underwater Robot Sonar Denoising
Sonar-based object detection with domain-space alignment and a new dataset.
Humanoid Whole-Body Control for Custom-Built Humanoid Robots
Reinforcement-learning whole-body controller for bespoke humanoid platforms.
Heterogeneous Multi-Robot Carrying System
Coordinated carrying with drones, ground wheeled robots, and humanoids.
Scroll horizontally to explore the project timeline
2024
[blog] Tools for Finding Research Papers